

Please see the Wiki for the EC463 hardware Miniproject.
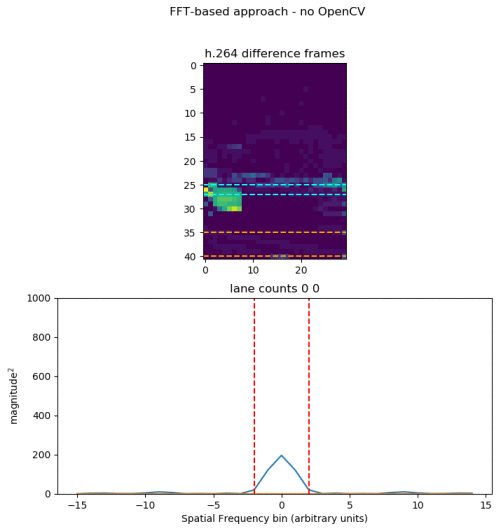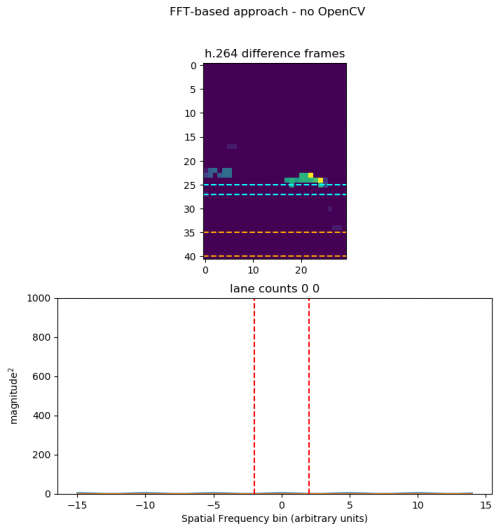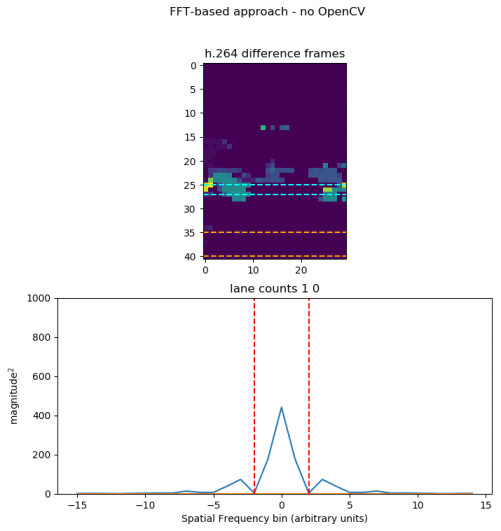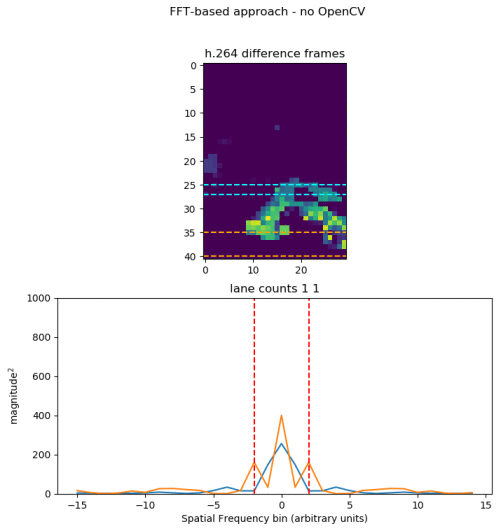
Machine learning / computer vision methods are not necessary for this task, thanks to the h.264 motion vectors output by the GPU from the Picamera. Since we know cars usually travel within a road lane, we can exploit this fact to greatly simplify the processing to be nearly 100x faster using plain Python or GNU Octave code than is achievable with OpenCV.
The file config.ini holds the parameters used to filter and plot the video. At the moment, up to four lanes of traffic can be configured--just leave lane(s) blank if you don't want to use them.
CaptureMotion.py
captures h.264 motion vectors from the camera as computed by the GPU, and stores them to motion.h5
CountMotion.py
counts moving objects in lanes using FFT of spatial motion data
For running the script automatically, it's handy to have a main script that calls CaptureMotion.py and then runs CountMotion.py. The script CaptureAndCount.py does this.